Modern warehouses are expected to move materials quickly while maintaining accurate inventory flow and predictable operations.
Industrial Warehouse Robotics AGV Systems address this challenge by using automated guided vehicles to transport pallets, containers, components, and other loads between defined locations.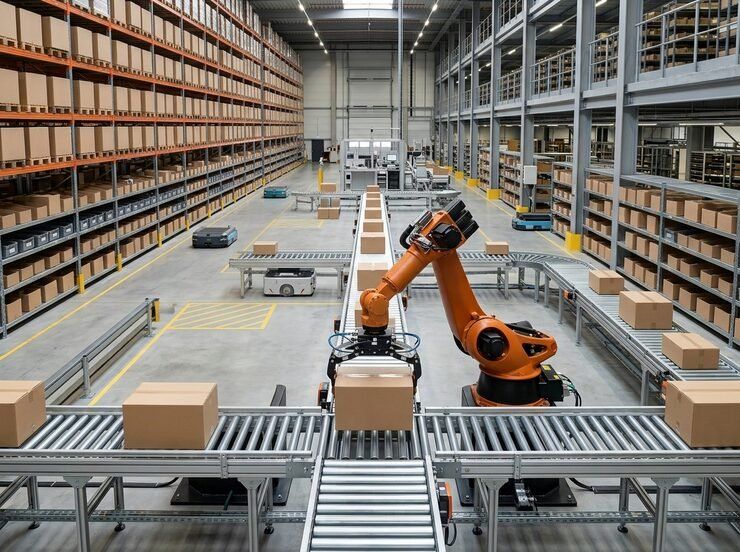
These systems have become increasingly relevant as warehouses handle greater product variety, tighter fulfillment schedules, and more complex internal movement patterns. Instead of relying entirely on manual transport, an AGV system can perform repeatable material-handling tasks according to programmed routes, warehouse controls, and operating rules.
Understanding how automated material movement works requires more than looking at the vehicle itself. The overall system includes navigation technology, fleet management, charging infrastructure, safety controls, warehouse software, and carefully designed workflows. Each element influences how effectively an AGV operates within a working facility.
How AGV Systems Move Materials Through a Warehouse
An automated guided vehicle is a mobile robotic platform designed to transport materials without continuous human driving. Depending on its configuration, an AGV may carry pallets, tow carts, move shelves, transport bins, or perform specialized handling tasks.
The vehicle receives movement instructions through a control system and navigates along an established path or defined operating area. Navigation can rely on technologies such as magnetic guidance, laser-based navigation, reflective markers, vision systems, inertial measurement, or mapped environments.
The exact approach depends on the warehouse layout and operational requirements. A simple facility may use predetermined routes, while a more dynamic environment may require sophisticated navigation and fleet coordination.
The result is a material movement process in which repetitive transportation tasks can be performed according to predefined rules rather than requiring an operator to drive each trip.
Key Components Behind Automated Material Movement
An AGV deployment is not simply a collection of autonomous vehicles. It functions as an integrated material-handling system in which several technologies work together.
The vehicle provides the physical movement capability, while sensors allow it to understand its surroundings and detect obstacles. Controllers interpret navigation information and determine how the vehicle should respond to its environment.
A fleet management system coordinates multiple vehicles when several AGVs operate simultaneously. It can assign missions, manage traffic, prioritize transport requests, and help prevent vehicles from interfering with one another.
Warehouse management systems and warehouse control systems can provide another layer of coordination. Depending on the architecture, these systems can communicate inventory or movement requirements to the AGV fleet, connecting automated transportation with broader warehouse operations.
Charging infrastructure is also part of the system. Vehicles need an appropriate charging strategy, whether that involves scheduled charging, opportunity charging, battery swapping, or another approach suited to operating conditions.
Navigation Technologies Used by AGVs
Navigation determines how an AGV knows where it is and where it needs to go. Different technologies provide different levels of flexibility.
Guided navigation uses physical or digital references that define the vehicle's route. Magnetic tape, wires, reflectors, or markers can provide guidance in environments where transportation paths remain relatively stable.
Laser-based navigation can allow vehicles to determine their position using environmental references. This approach can support more flexible layouts because the vehicle does not necessarily depend on a continuous physical guide path.
Vision-based navigation uses cameras and computer vision to interpret environmental features. Depending on the system, visual information can help with positioning, obstacle detection, and navigation.
Natural-feature navigation allows robotic vehicles to use characteristics already present in the facility rather than requiring extensive physical guidance infrastructure. This can be useful when warehouse layouts change periodically.
The appropriate navigation method depends on factors such as floor conditions, route complexity, environmental changes, positioning accuracy, and integration requirements.
How AGVs Fit Into Warehouse Workflows
The greatest value of an AGV system comes from how well it fits the warehouse's existing material flow.
A typical workflow may begin when a warehouse system generates a transportation request. The fleet management layer assigns the task to an available vehicle. The AGV travels to the pickup location, receives or collects the load, and moves it to the designated destination.
At the destination, the system confirms that the material has reached the appropriate location. Depending on the application, the AGV may then receive another mission, return to a staging area, or proceed to a charging point.
This creates a continuous transportation loop rather than isolated robotic movements. The system's performance therefore depends on the coordination between physical vehicles, warehouse processes, software, and human operators.
Safety and Human-Robot Interaction
Safety is a fundamental part of industrial mobile robotics. AGVs commonly use sensors and control systems designed to detect obstacles, identify people or equipment in their path, and respond according to configured safety requirements.
Facilities also need clearly defined traffic rules. Pedestrian walkways, vehicle routes, loading zones, intersections, restricted areas, and emergency procedures should be considered during system design.
Industrial safety frameworks and risk-assessment practices help organizations determine appropriate protective measures. The exact requirements vary according to the equipment, facility, jurisdiction, and application.
Human interaction remains important even in highly automated warehouses. Workers may load materials, supervise operations, handle exceptions, perform maintenance, or interact with vehicles during routine activities.
Good system design therefore considers people and robots as participants in the same operating environment rather than treating automation as a completely separate process.
Where AGV Systems Are Commonly Used
AGVs are particularly useful when material movement is repetitive, predictable, or physically demanding. Their applications can vary significantly depending on warehouse design.
Common uses include:
- Pallet transportation between receiving and storage areas
- Movement between storage and production zones
- Cart or trailer towing
- Replenishment of warehouse workstations
- Finished-goods movement
- Transfer between staging and shipping areas
- Transportation of containers or components
The most suitable application is usually one where the movement pattern occurs frequently enough to justify structured automation.
AGVs can also operate alongside conveyors, automated storage and retrieval systems, robotic arms, palletizing equipment, and warehouse software. In these environments, the vehicle becomes one component of a larger automated material-flow architecture.
Designing an Effective AGV Deployment
A successful deployment begins with understanding the warehouse rather than selecting a vehicle first.
Material characteristics are one consideration. Pallet dimensions, load weight, container types, stability, and pickup requirements influence the vehicle configuration.
Warehouse geometry matters as well. Aisle width, turning radius, floor conditions, doorways, ramps, intersections, and traffic density can determine whether an AGV can move reliably through the facility.
Operational demand is another major factor. Organizations need to understand how many transport missions occur during different periods and how quickly those missions need to be completed.
A useful assessment typically examines:
- Material flow between locations
- Transportation frequency
- Load characteristics
- Route distances
- Traffic patterns
- Required vehicle capacity
- Charging requirements
- Human interaction points
- Software integration
- Exception-handling procedures
This analysis helps define the actual automation requirement instead of treating robotics as a standalone technology purchase.
Managing Fleets Instead of Individual Vehicles
When multiple AGVs operate together, fleet management becomes increasingly important. Sending vehicles through the same warehouse without centralized coordination can create congestion, inefficient routing, and unnecessary waiting.
Fleet management software can distribute transportation tasks across available vehicles while considering factors such as location, workload, battery status, priority, and route availability.
Traffic management is particularly important at intersections and shared corridors. The system may assign priorities or alternative routes to reduce conflicts.
Fleet performance can also be monitored through operational data. Metrics such as vehicle utilization, mission completion, idle time, charging activity, travel distance, and task queues can help identify bottlenecks.
The objective is not simply to maximize the number of vehicles. An appropriately coordinated fleet should support material flow without creating new congestion within the warehouse.
Challenges That Affect AGV Performance
AGVs can automate repetitive transportation, but they do not eliminate operational complexity.
Changing warehouse layouts can require navigation adjustments or system reconfiguration. Unexpected obstacles, damaged pallets, blocked aisles, software communication failures, and unusual loads can also interrupt automated workflows.
Battery management requires planning because vehicles cannot transport materials indefinitely without replenishment. Poorly planned charging can reduce fleet availability during periods of high demand.
Integration can present another challenge. An AGV fleet may need to communicate with warehouse management software, warehouse control systems, conveyors, storage systems, elevators, doors, and other automation equipment.
Maintenance is equally important. Sensors, drive systems, batteries, communication equipment, and mechanical components all require appropriate inspection and servicing.
These considerations show why AGV deployment is fundamentally an operational engineering project rather than simply a robotics installation.
The Role of AGVs in Connected Warehouses
As warehouse automation becomes more interconnected, AGVs increasingly operate as part of a broader digital environment. Real-time equipment data can support fleet coordination, workflow monitoring, maintenance planning, and operational analysis.
Integration with warehouse management platforms can connect transportation tasks with inventory movement. Industrial networks can provide communication between vehicles and facility equipment, while centralized software can provide visibility across automated operations.
This creates opportunities for more adaptive material movement. Instead of treating every transportation task as an isolated trip, the warehouse can coordinate movement based on current workloads, inventory requirements, equipment availability, and traffic conditions.
The practical goal remains straightforward: move the right material to the right location at the appropriate time while maintaining safe and predictable warehouse operations.
Conclusion
Industrial Warehouse Robotics AGV Systems provide a structured approach to automated material movement by combining mobile robots, navigation technologies, fleet management, safety systems, and warehouse software.
Their effectiveness depends on more than vehicle capabilities. Warehouse layout, material characteristics, traffic patterns, charging strategies, software integration, and human interaction all influence system performance.
When these elements are designed as one coordinated workflow, AGVs can become an important part of modern warehouse material handling. The technology is most useful when automation is matched carefully to the physical and operational realities of the facility.